
1/3
Abuja, Gwarinpa, 1 day ago
9 views
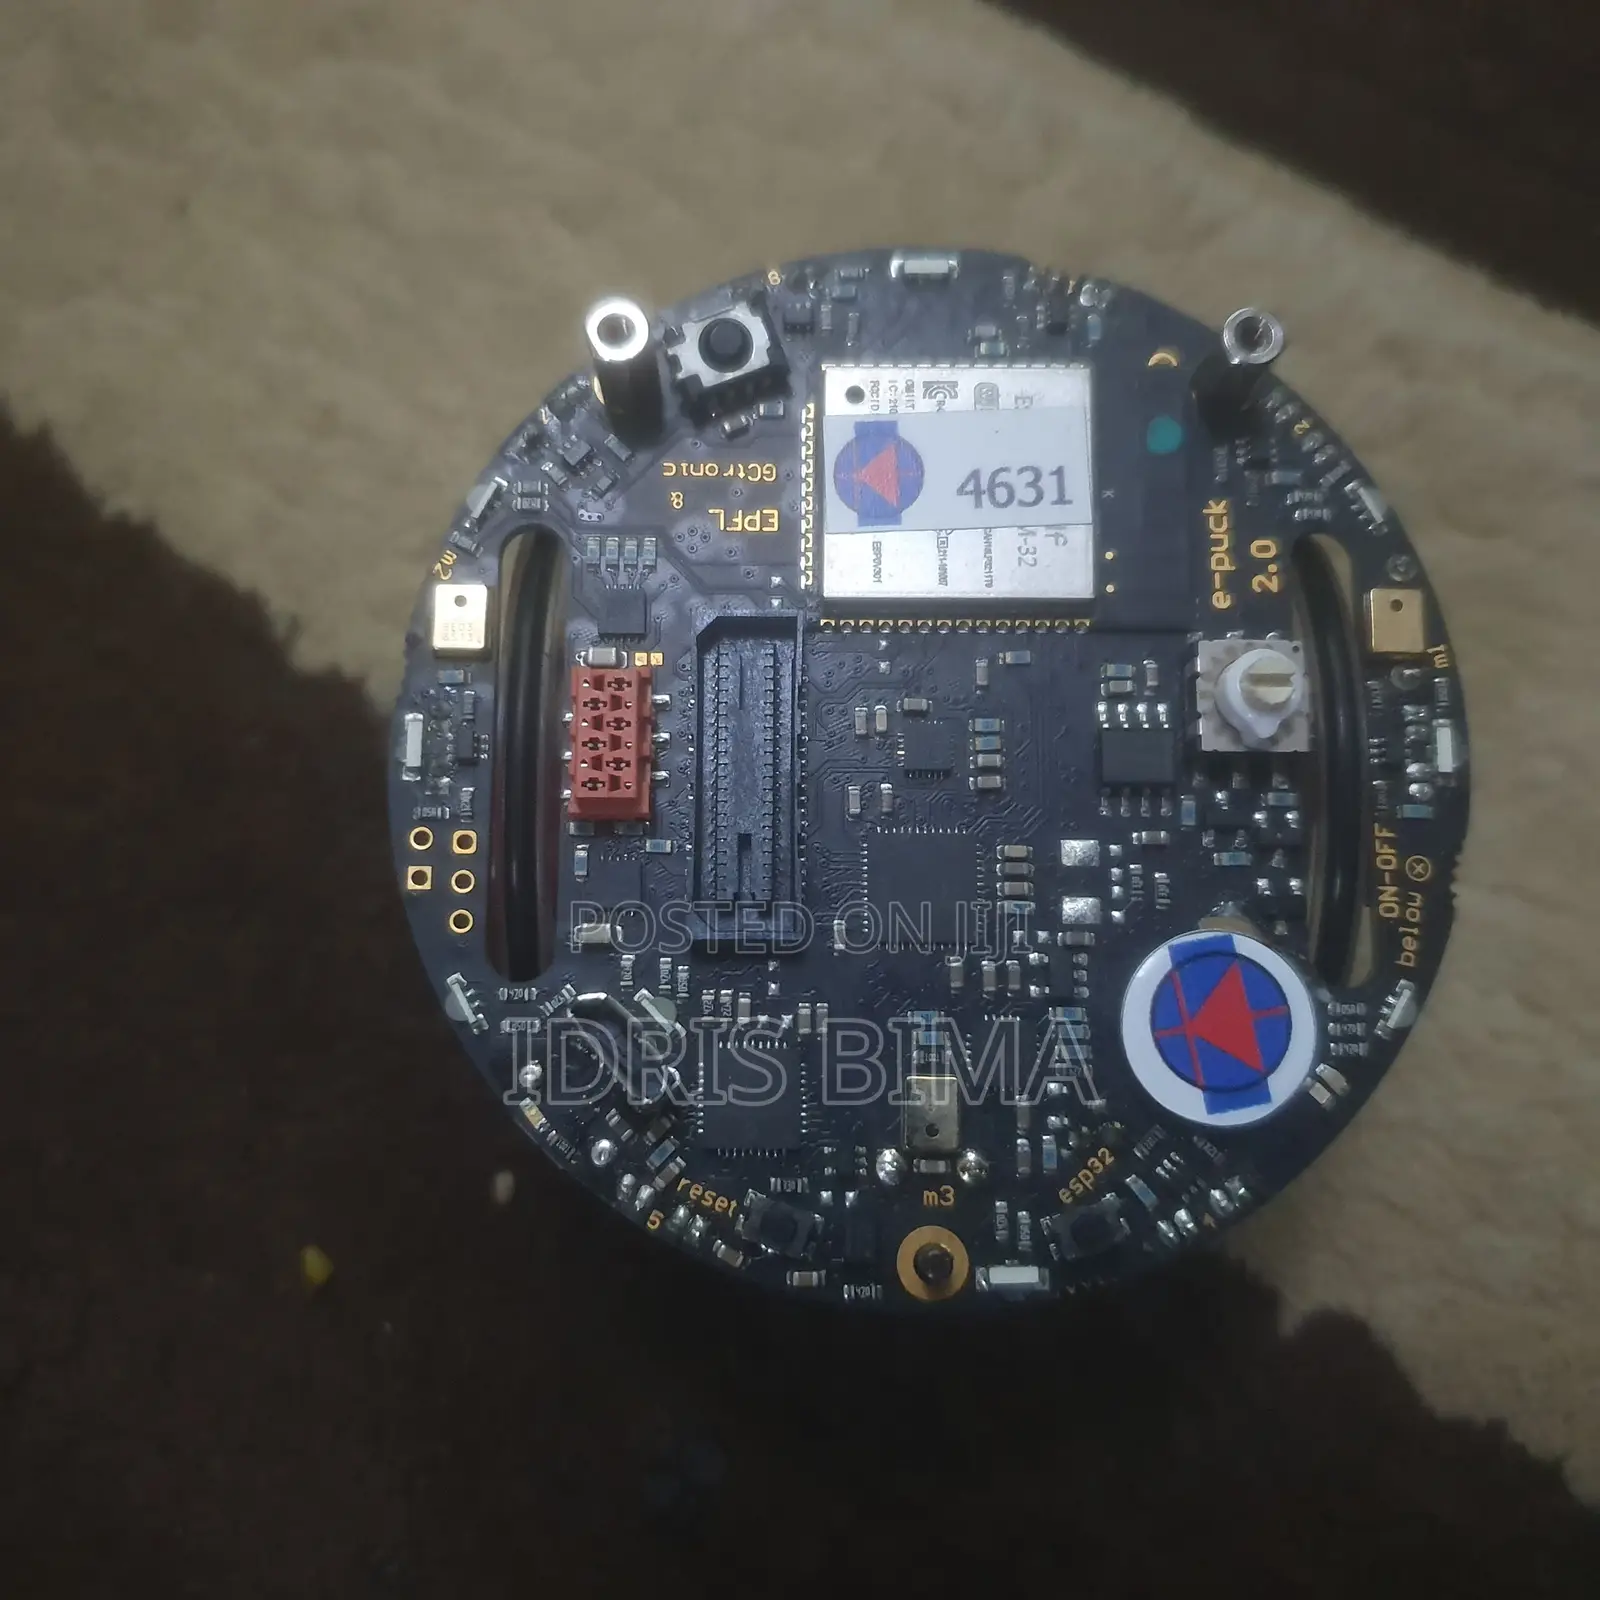
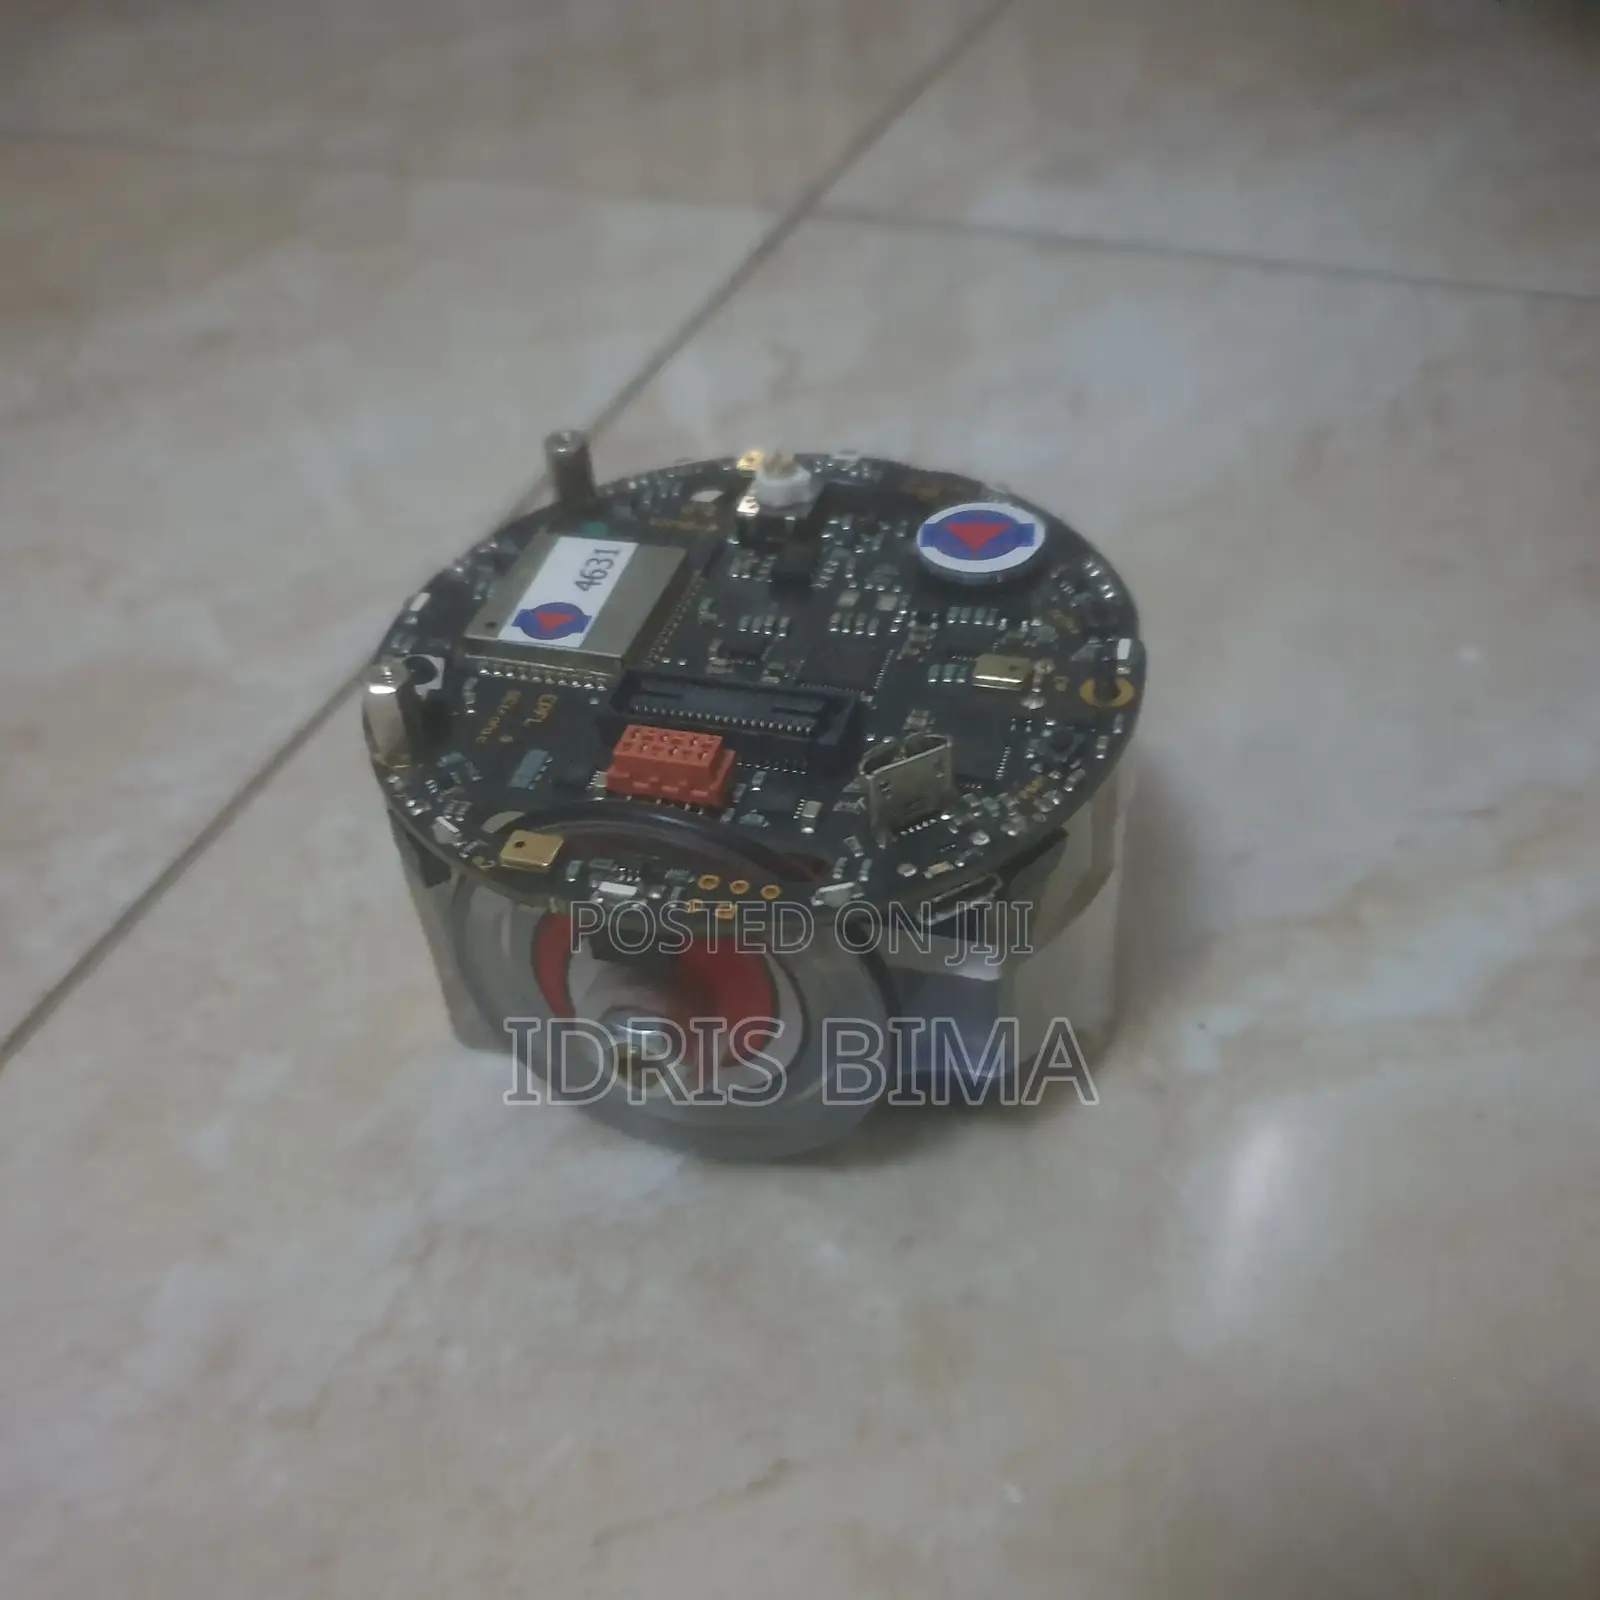
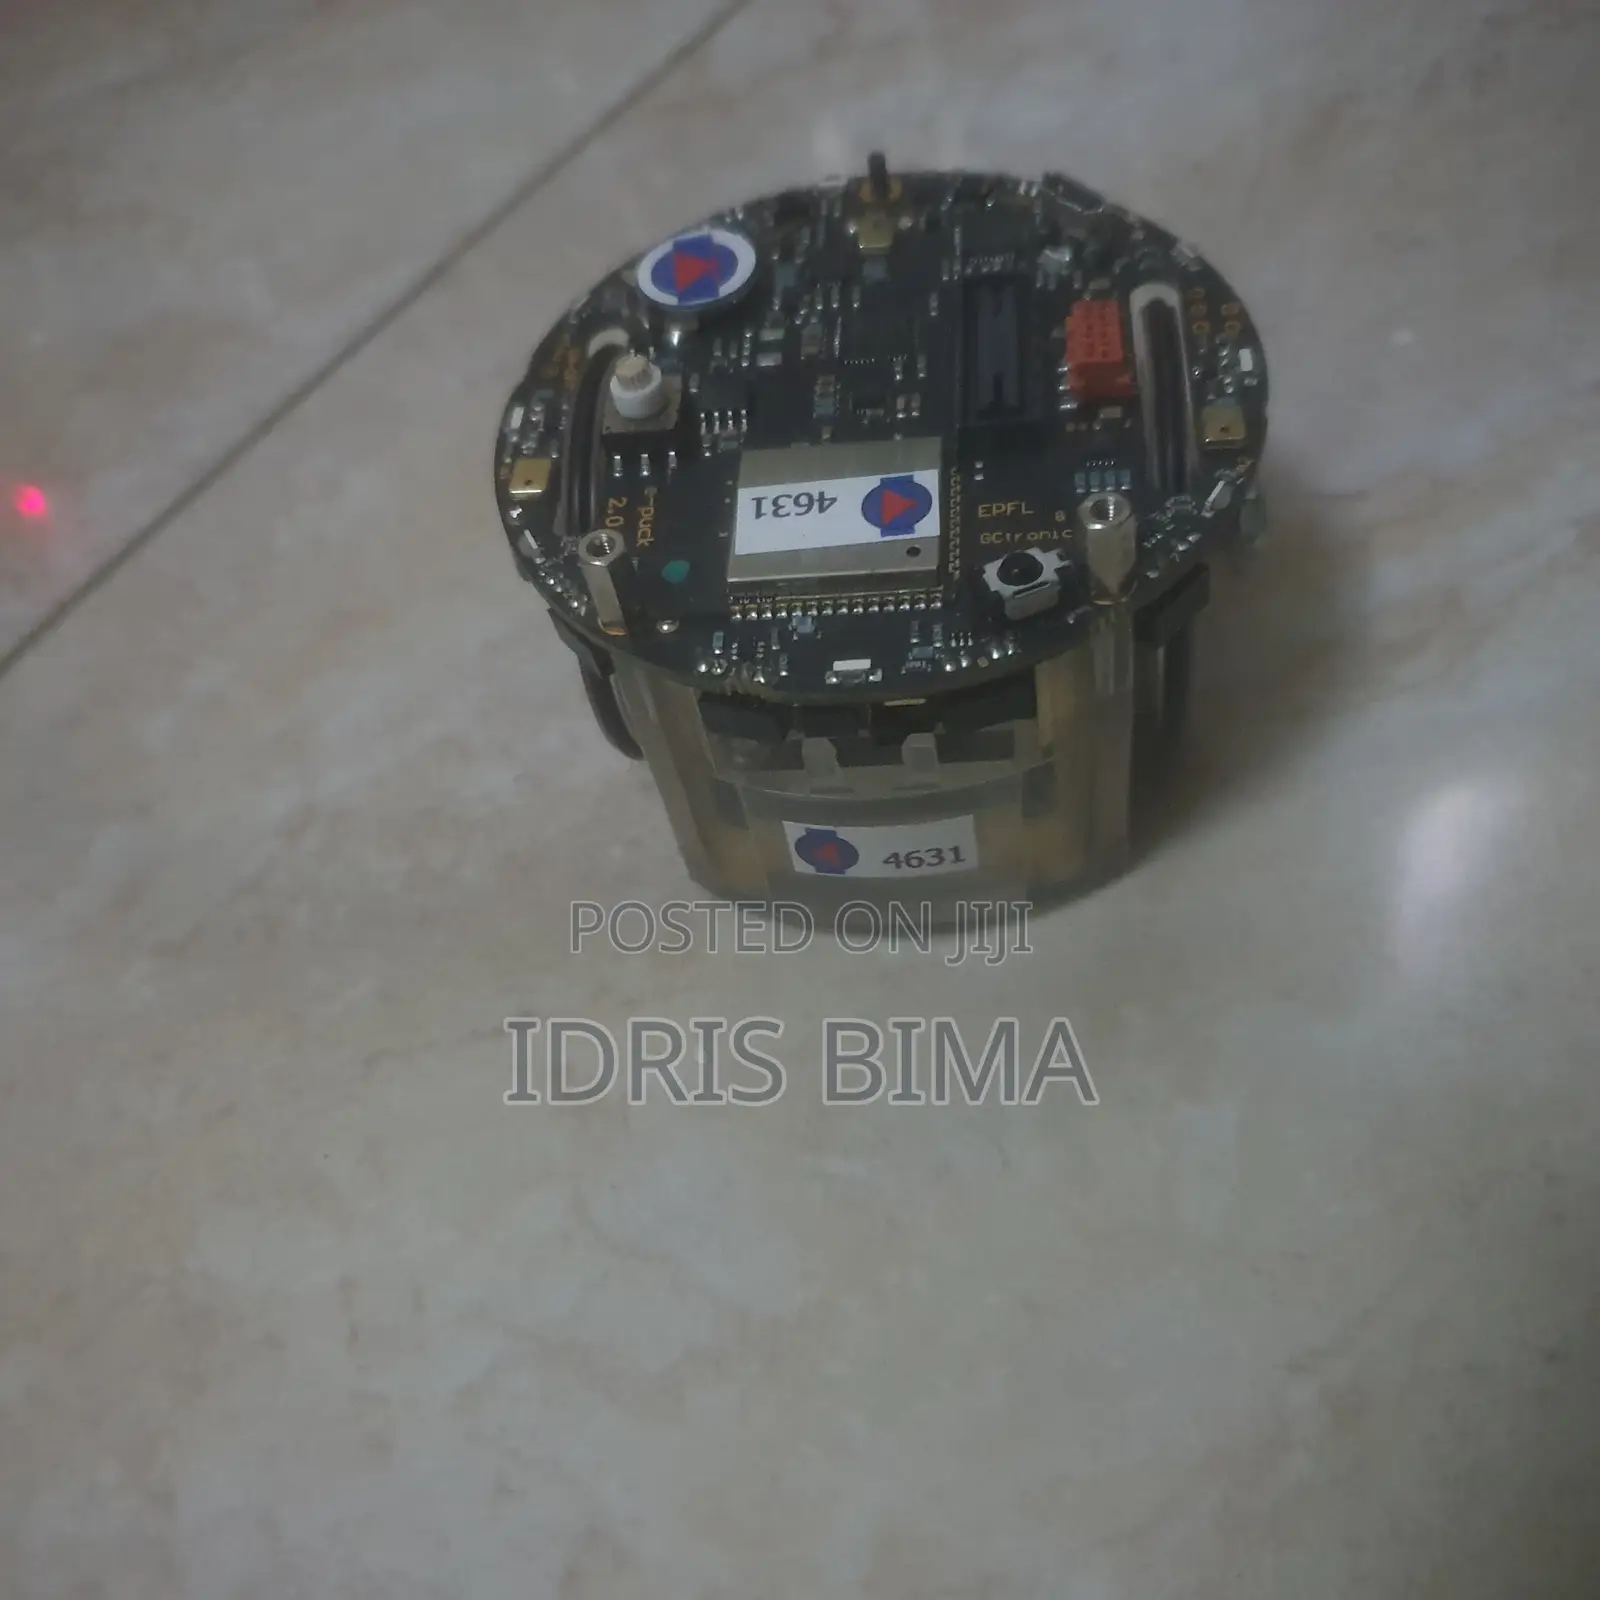
Epuck2 Robot
Robots
Type
epuck
Brand
Unisex
Gender
Used
Condition
This is an epuck2 Robot which has
Kinematics & Orientation (IMU)
• Accelerometer: Measures 3D linear acceleration to detect movement and impact.
• Gyroscope: Measures 3D angular velocity to track rotational speed and orientation.
• Magnetometer: Acts as a 3D digital compass to detect magnetic fields and orientation relative to the Earth.
Environmental & Proximity
• Infrared (IR) Sensors: 8 proximity sensors distributed around the ring of the body to detect obstacles up to ~6 cm away.
• Ambient Light Sensors: The same 8 IR sensors can double as light intensity detectors to measure surrounding brightness.
Audio
• Microphones: 4 omnidirectional digital microphones arranged around the robot, allowing it to detect sound presence and perform sound source localizatio
₦ 850,000
NegotiableSafety tips
- Avoid paying in advance, even for delivery
- Meet with the seller at a safe public place
- Inspect the item and ensure it's exactly what you want
- Make sure that the packed item is the one you've inspected
- Only pay if you're satisfied


